Hand-Eye Calibration Program
Program that aligns a robot-mounted sensor with the robot coordinate system
It finds the transform between a sensor mounted on the robot hand and the robot coordinate system. It calculates the result from scans of one sphere on a post, taken from several poses.
Features
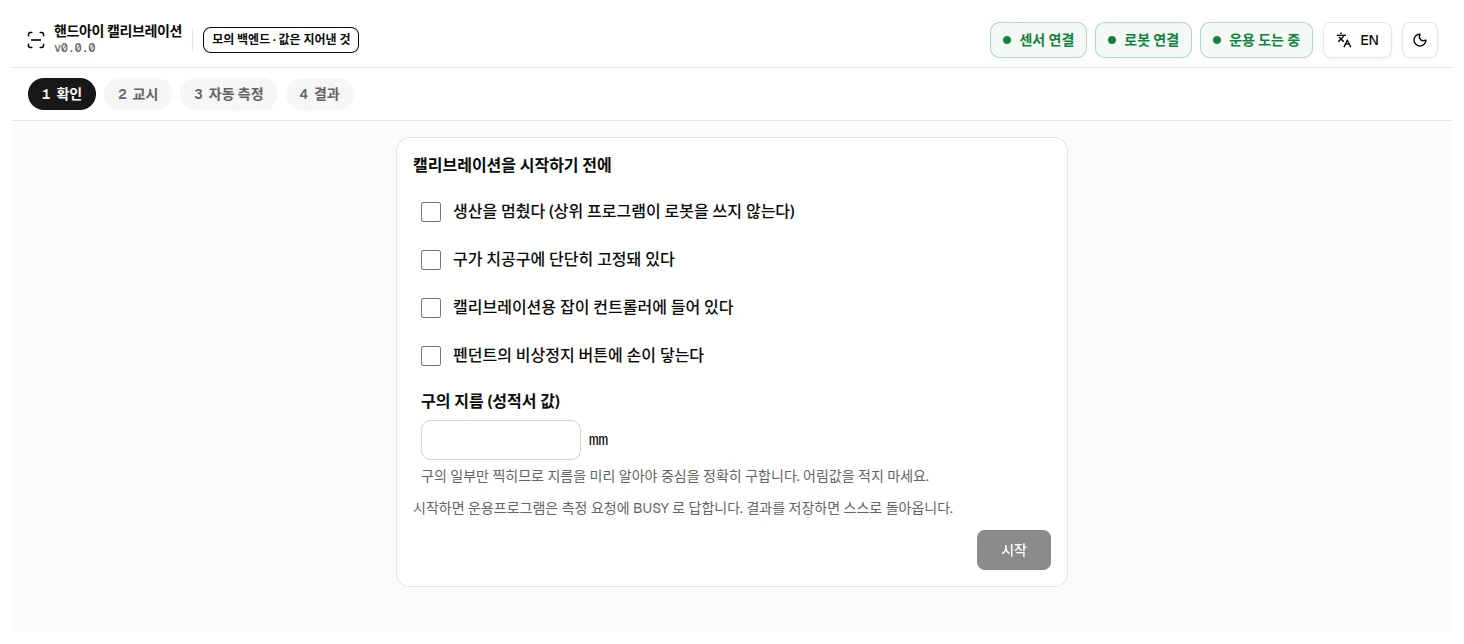
- Four steps on one screen: check → teach → automatic measurement → result
- Finds only the sphere center, so no shape-matching calculation is needed
- Judges the result by the error of verification poses that the calculation did not use
- Only the stop button is available during automatic measurement
- Poses with a large error can be measured again
Note: The screens and a simulated run are complete. The connection to a real robot and sensor is in development.
Specifications
| Reference object | One sphere (enter the diameter from its certificate) |
|---|---|
| Number of poses | 9, 12 or 16 for calculation, 2 for verification |
| Steps | Check, teach, automatic measurement, result |
| Screen language | Korean, English |
Screens
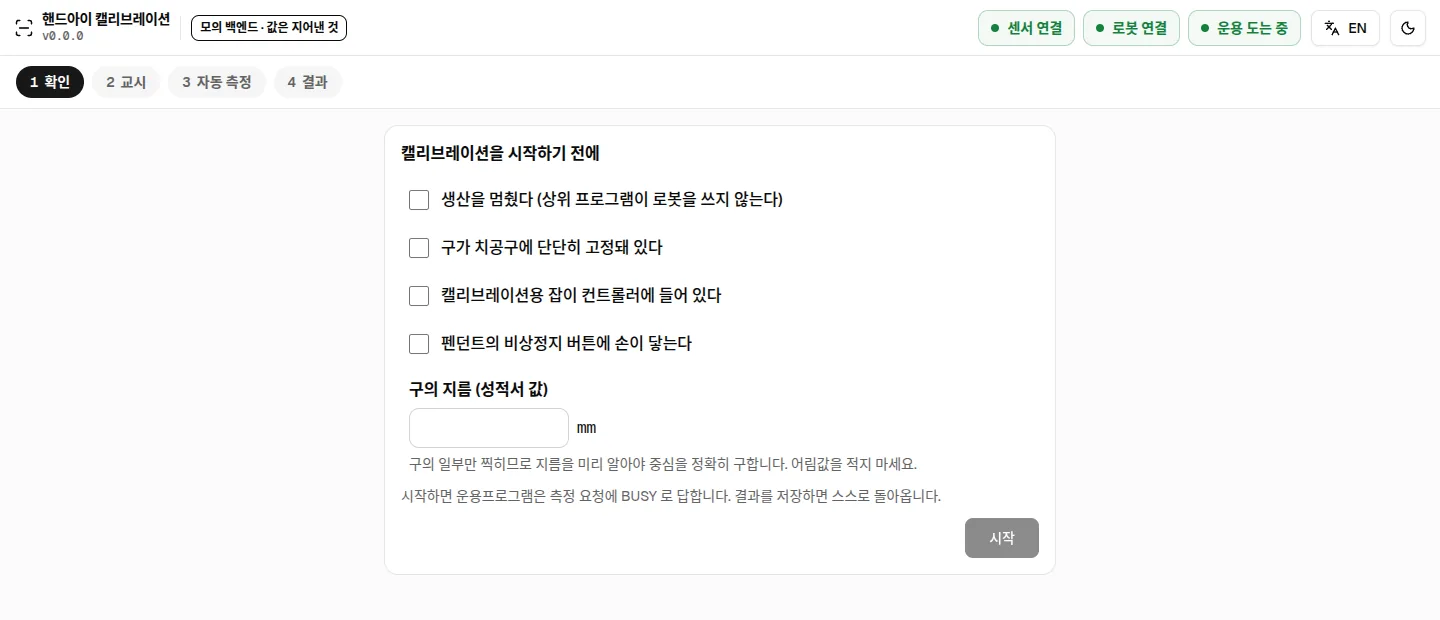
Products in the same category
Need a different specification?
We develop dedicated versions with the channel count, connectors and communication method changed to fit your machine.